The public side of our engineering work.
We publish only the projects we can share openly. Work carried out directly with defense departments is not listed here.
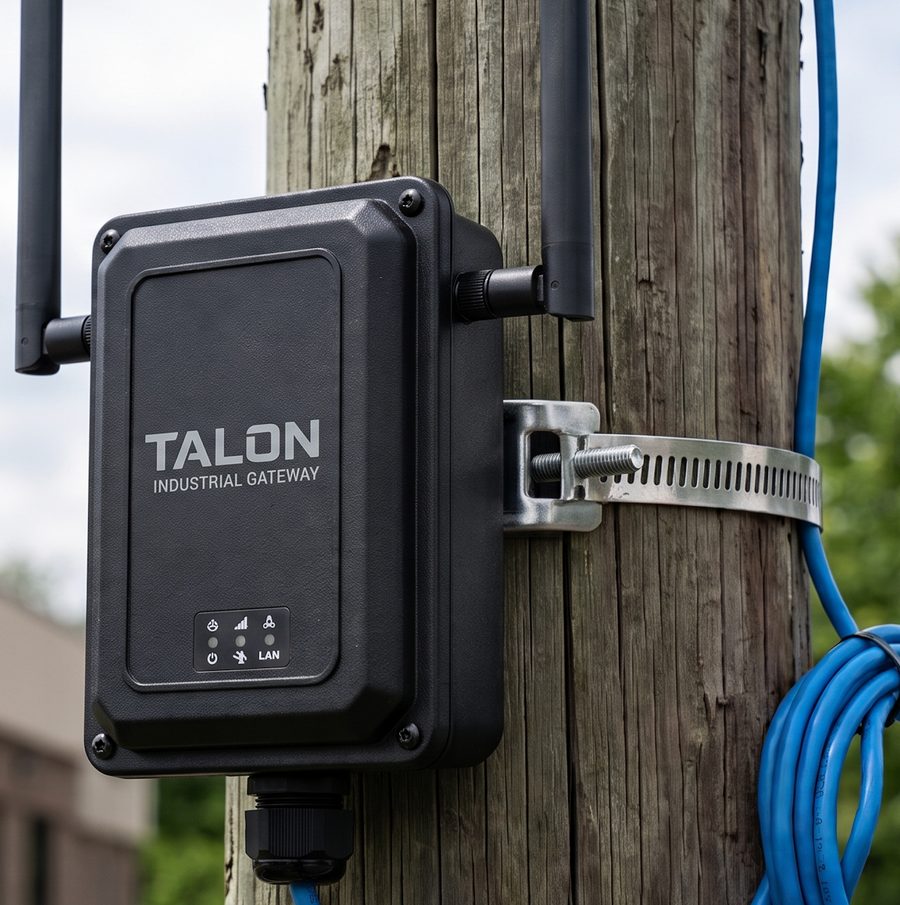
TALON
Tactical Awareness, Location & Operations Network
An autonomous IoT mesh network that detects wildlife and intruders in deep forest where there is no cellular coverage. TALON pairs a Wi-Fi HaLow (IEEE 802.11ah) data mesh with an independent LoRa channel. HaLow's sub-1 GHz band penetrates dense canopy far better than conventional Wi-Fi, and the LoRa channel carries SOS alerts and short MAYDAY voice messages even when the data mesh degrades.
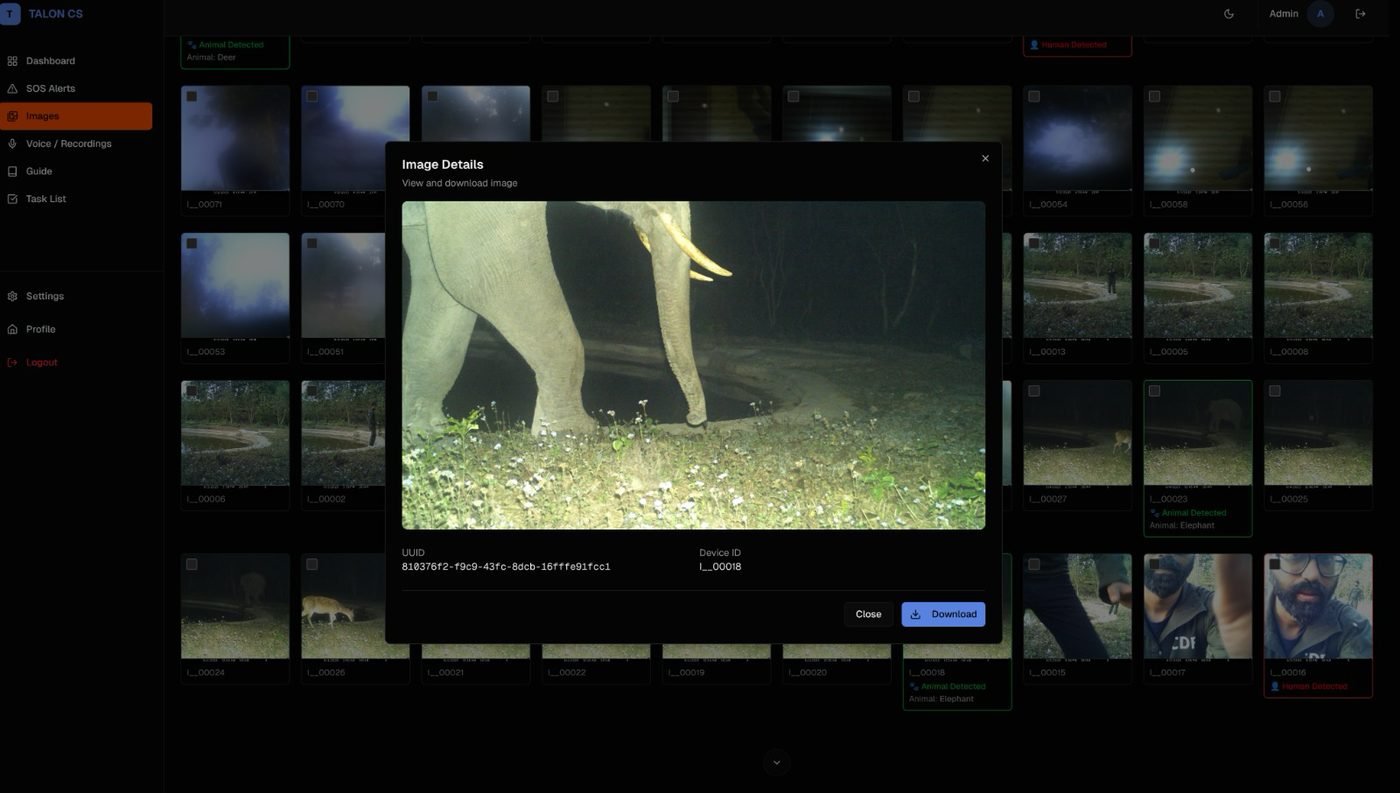
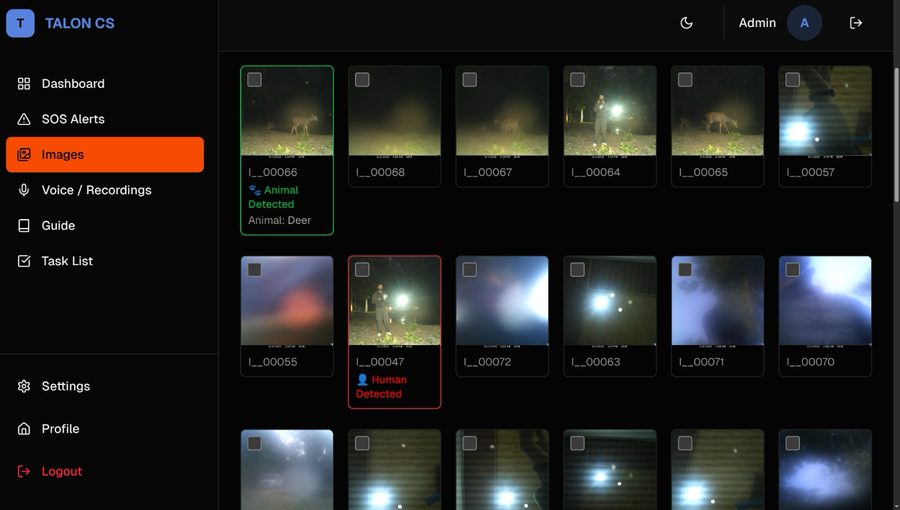
Camera nodes fetch images from attached trail cameras and inject them into the mesh, where store-and-forward routing carries them hop by hop to a command gateway. The architecture tolerates intermittent links and is designed to chain across hundreds of kilometres of forest. A detection reaches rangers within two to three minutes of the event, with nobody present at the node.
TALON's first field trial ran for 14 hours overnight in a Uttarakhand forest division in February 2026, with the state forest department. A five-node chain captured and delivered every image it detected in near real time, among them a tusker (Asian elephant), sambar deer and spotted deer. All five nodes held the network through the night with no dropout and no manual intervention.
In development
Early-stage initiatives. Details will be published as each reaches field readiness.
Disaster-response comms kit
Portable mesh communications for teams operating where infrastructure has failed.
TALON Edge device
GPS-enabled edge node with an integrated camera and IR night vision. It feeds event-triggered captures into the TALON mesh.
Low-cost welfare sensing
Affordable environmental and safety sensing for under-served communities.
Acoustic classification models
On-device models to distinguish threat sounds from ambient forest audio.